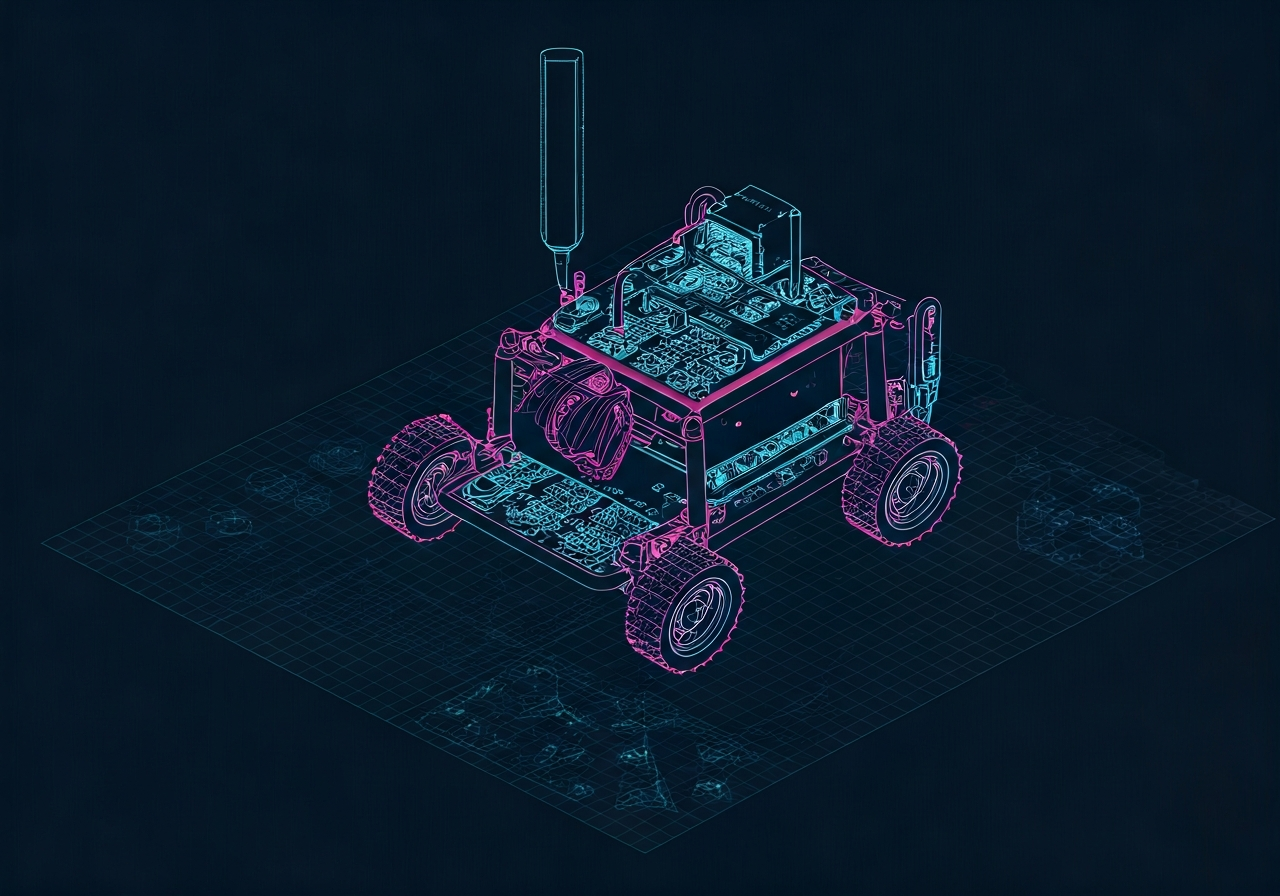
CocoaScout RTK: Autonomer Rover zur Bodenanalyse
Ein robuster, autonomer 4WD-Rover für dichte Kakaoplantagen, der RTK-GPS und LiDAR für die präzise Kartierung der Bodengesundheit nutzt. Sein motorisiertes Sondensystem erfasst NPK- und Feuchtigkeitswerte vollautomatisch und synchronisiert sie via MQTT für das Farmmanagement in Echtzeit.
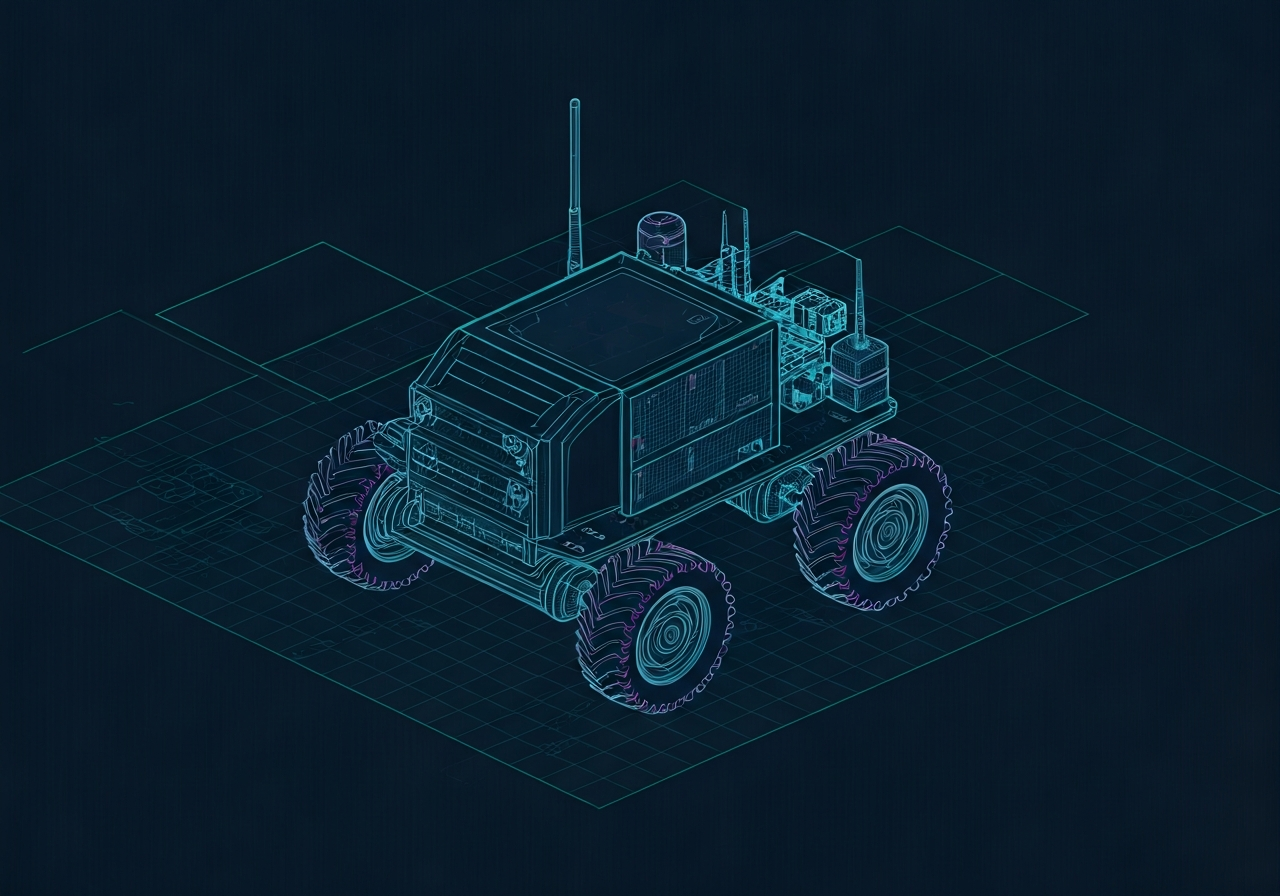
Original prompt (Englisch)
Design an autonomous cocoa farm monitoring robot using Jetson Nano 4GB. The robot navigates between RTK-GPS waypoints, avoids obstacles, and collects soil data at predefined locations. At each setpoint, a linear actuator lowers a soil probe into the ground to measure moisture, temperature, pH, EC, and NPK, then retracts it before continuing. Include a rugged chassis for muddy terrain, 4WD or tracked locomotion, LiDAR, camera, ROS integration, MQTT communication, power system, electronics architecture, BOM, and CAD-ready mechanical concepts.
Like this idea? Build it.
Open the Builder pre-filled with this concept. Get a real BOM, render, schematic and firmware in 30 seconds.