Community idea
Open Source Quasi Direct Drive Biped Humanoid
A compact, open-source humanoid robot powered by high-torque quasi-direct-drive actuators for dynamic balancing and natural locomotion. It lowers the barrier to advanced bipedal robotics research and expressive teleoperation using accessible fabrication methods.
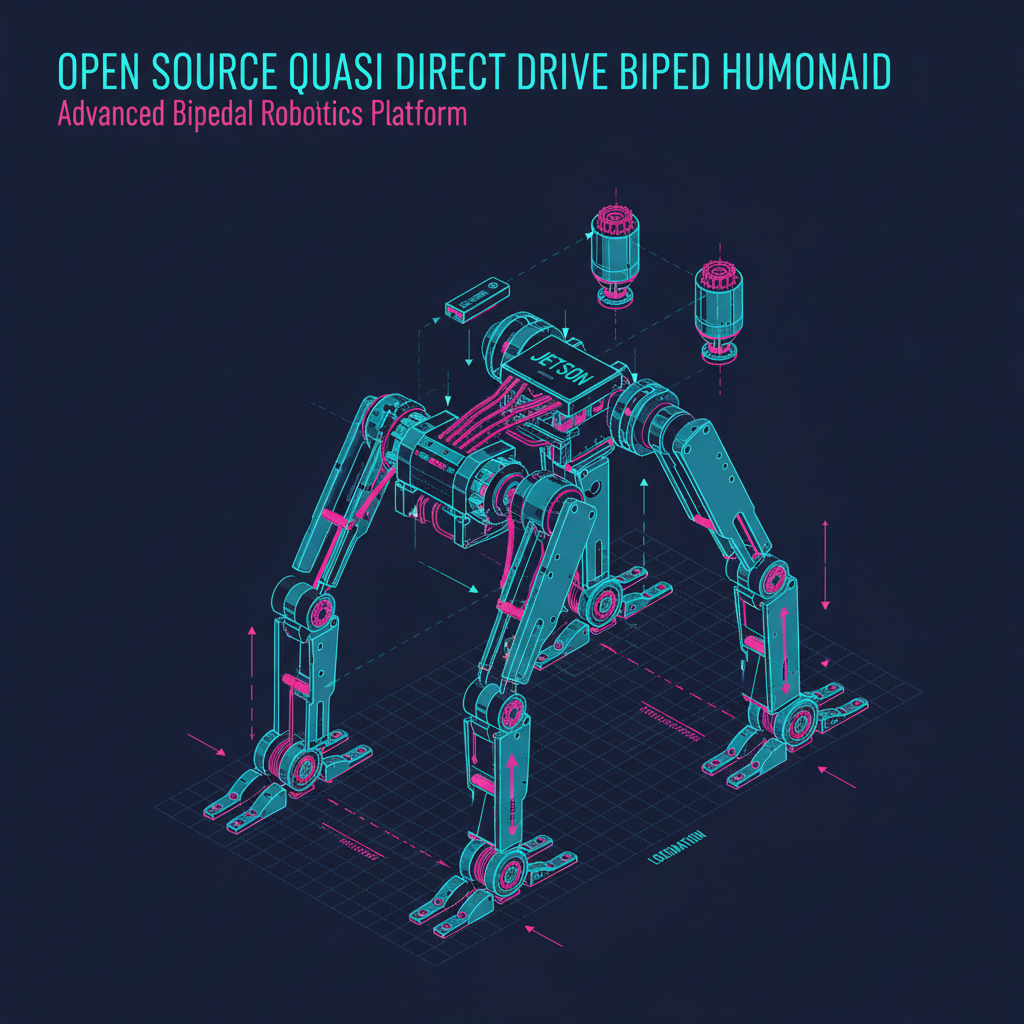
AI sketch · RoboHub AI
0 upvotes👁️ 1 views
Original prompt (English)
humanoid
Like this idea? Build it.
Open the Builder pre-filled with this concept. Get a real BOM, render, schematic and firmware in 30 seconds.
Related ideas
Comments (0)
Markdown supported (**bold**, links, lists)
…