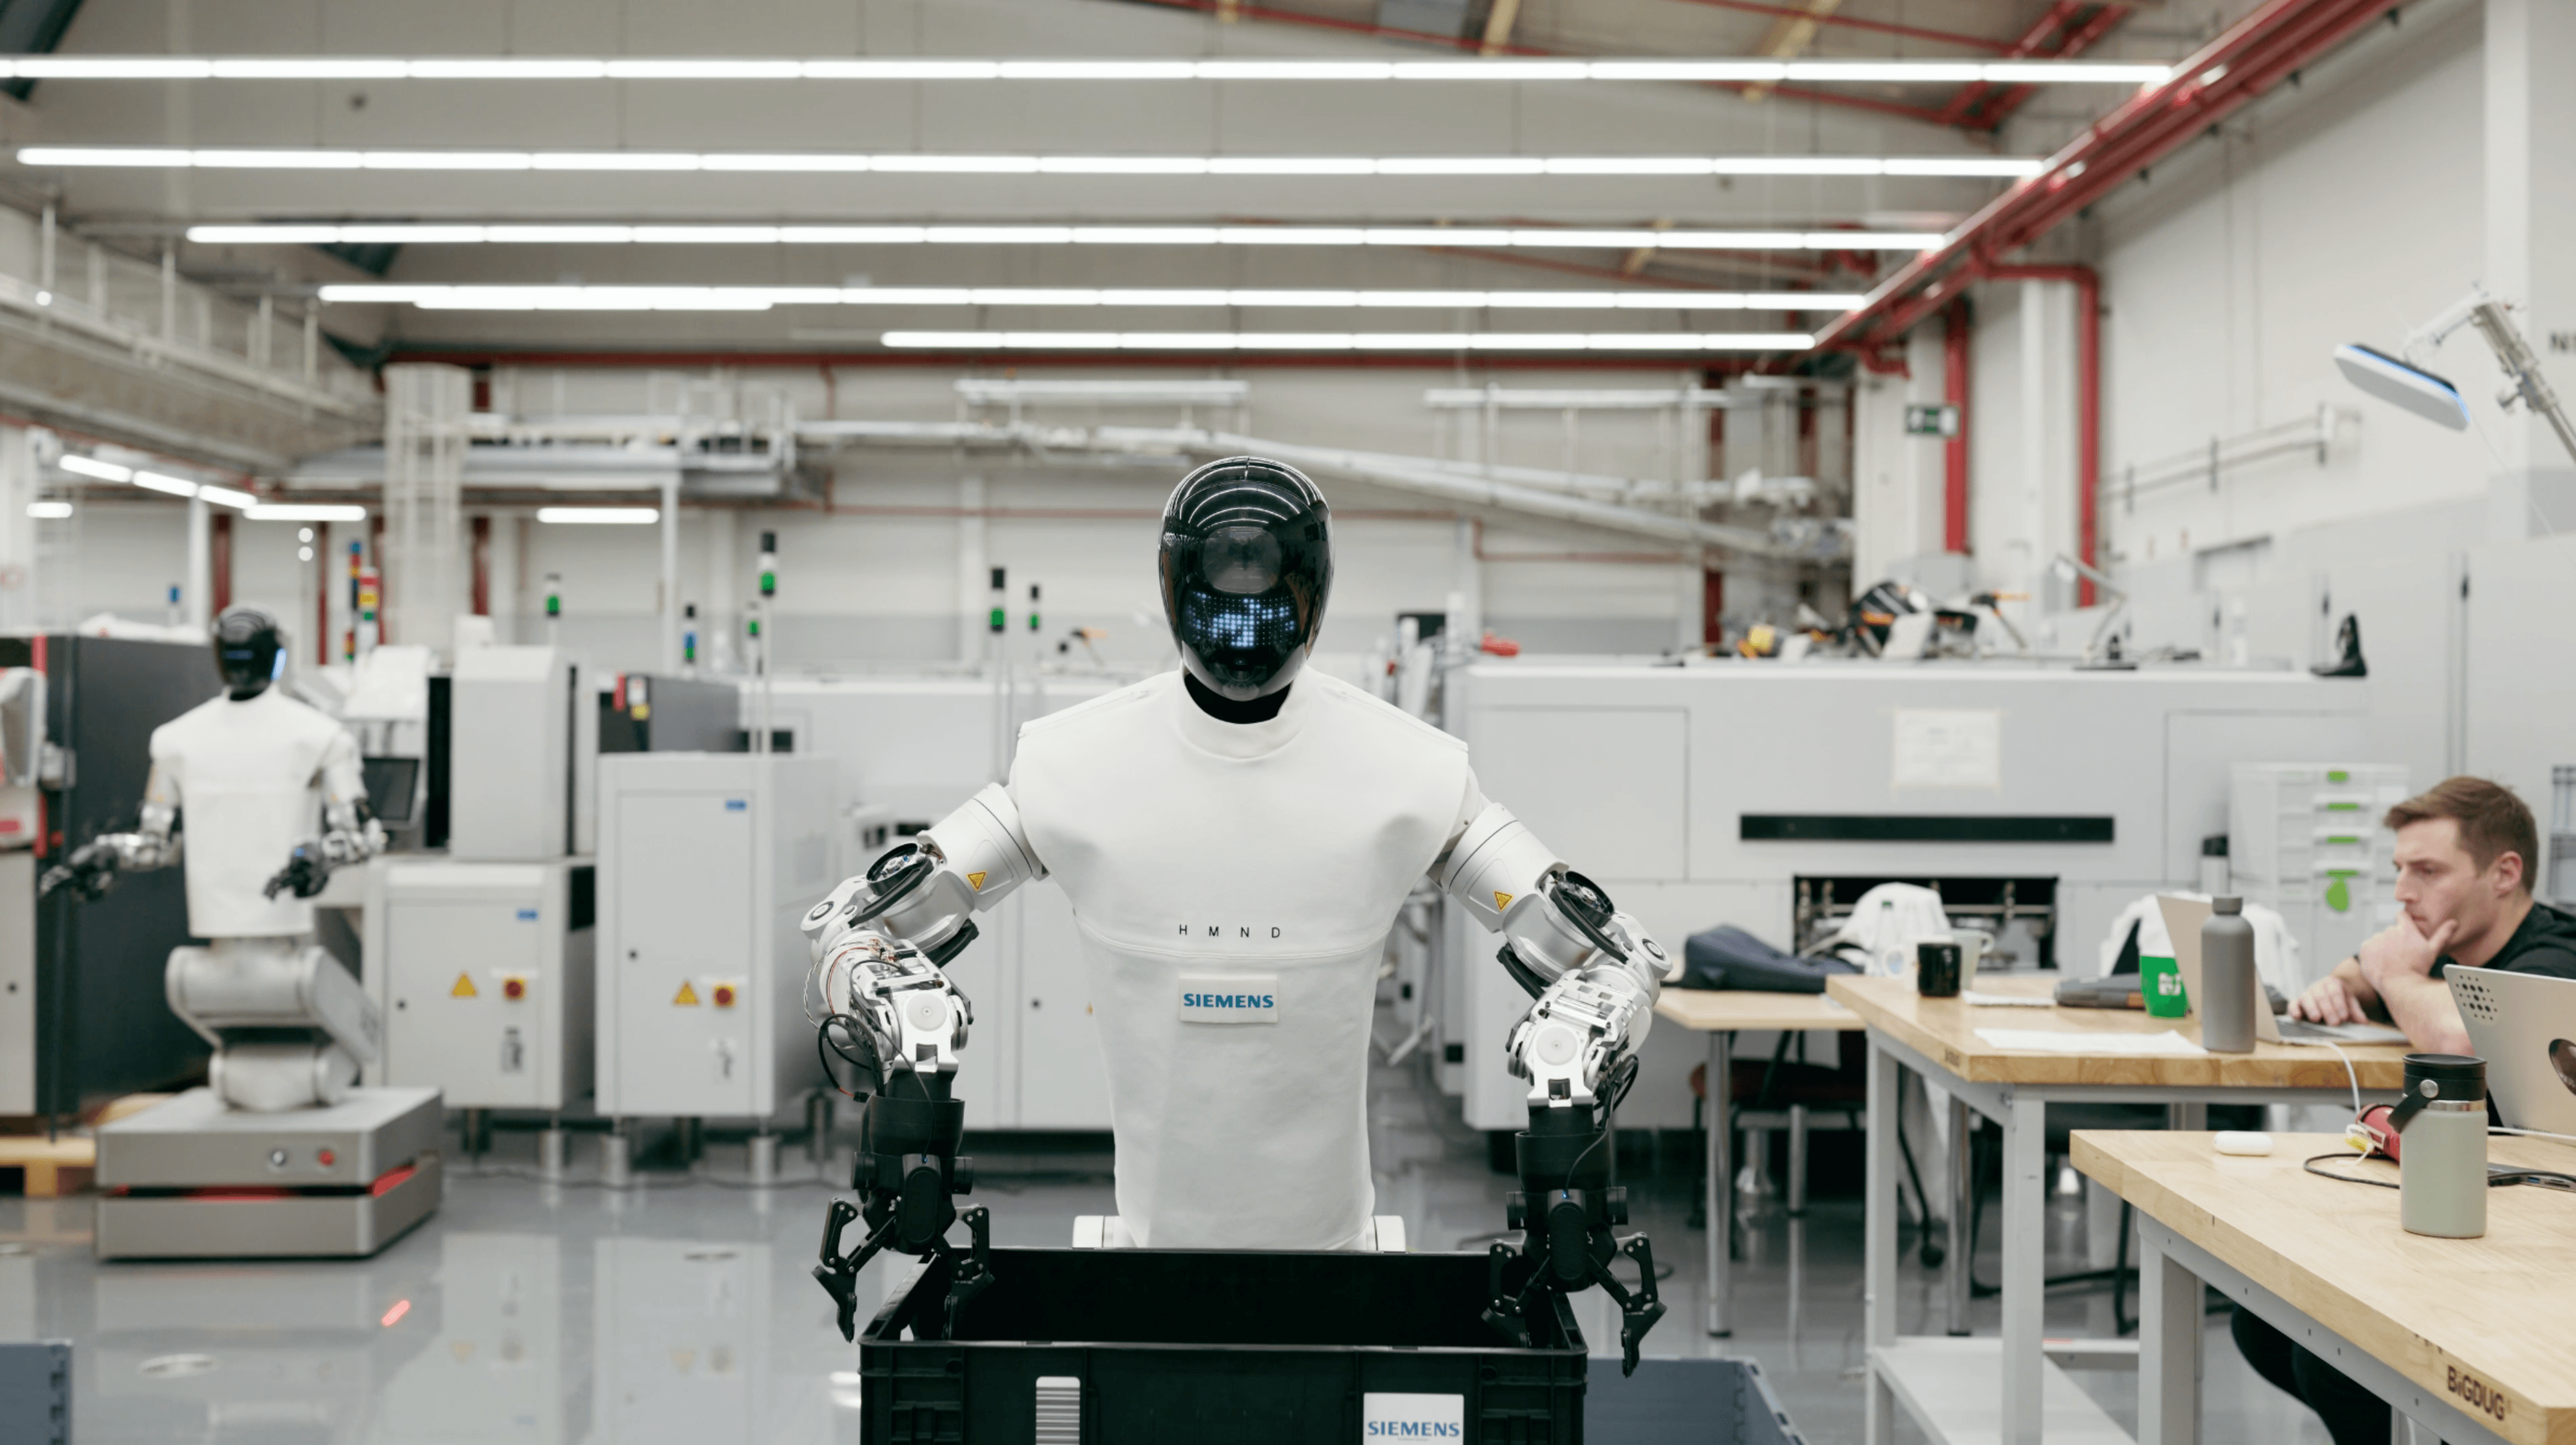
Humanoid expands NVIDIA work on robot edge runtime
Humanoid is developing an onboard runtime with NVIDIA for its next generation of robots, building on existing simulation and training work.
An onboard foundation for future robots
Humanoid, the UK robotics company, announced on 2026-10-21 that it is expanding its collaboration with NVIDIA to develop a robotic edge runtime for its next generation of humanoid robots. The work is intended to bring sensing, AI and control together onboard, with Humanoid describing a foundation for more sophisticated models to perceive, reason and respond to the physical world.
The planned architecture brings together NVIDIA Jetson Thor onboard compute, NVIDIA Isaac OS, NVIDIA Holoscan Sensor Bridge and NVIDIA Holoscan SDK. According to Humanoid, these technologies will support sensor-data processing, onboard AI and coordination between perception, reasoning and control. The release frames those capabilities as part of its next-generation development work.
Extending an existing simulation workflow
The collaboration builds on NVIDIA tools already used in Humanoid's development process. The company says it has worked with NVIDIA Isaac Lab and NVIDIA Isaac Sim since its early days to train and simulate models before running them on physical robots.
Humanoid presents the runtime work as a continuation of that workflow, connecting training and simulation with onboard operation. It says the architecture can reduce unnecessary data movement and simplify how robotics workloads share computing resources. Those are the maker's stated benefits; the announcement does not present measured results from a deployed robot using the complete new runtime.
Keep the announcement and catalog context distinct
The Humanoid announcement does not name the robot model that will receive this runtime. Humanoid's current robot (HMND 01 Alpha Wheeled) provides separate product context, without establishing that it is the recipient.
RoboHub's Humanoid brand hub and humanoid robot directory place the company within the wider catalog. The Jetson Thor catalog context is a component reference, rather than evidence of integration into any particular robot model.
Need this kind of robot for your operation?
Send us the use case. We return a vendor-neutral shortlist, indicative pricing, and warm vendor contacts.
Build a prototype inspired by HMND 01 Alpha Wheeled
Configure BOM, actuators, sensors, and compute for a DIY prototype inspired by Humanoid HMND 01 Alpha Wheeled.
Compare HMND 01 Alpha Wheeled vs AgiBot A2
Compare HMND 01 Alpha Wheeled directly with AgiBot A2, selected from catalog entries with sufficiently complete data.