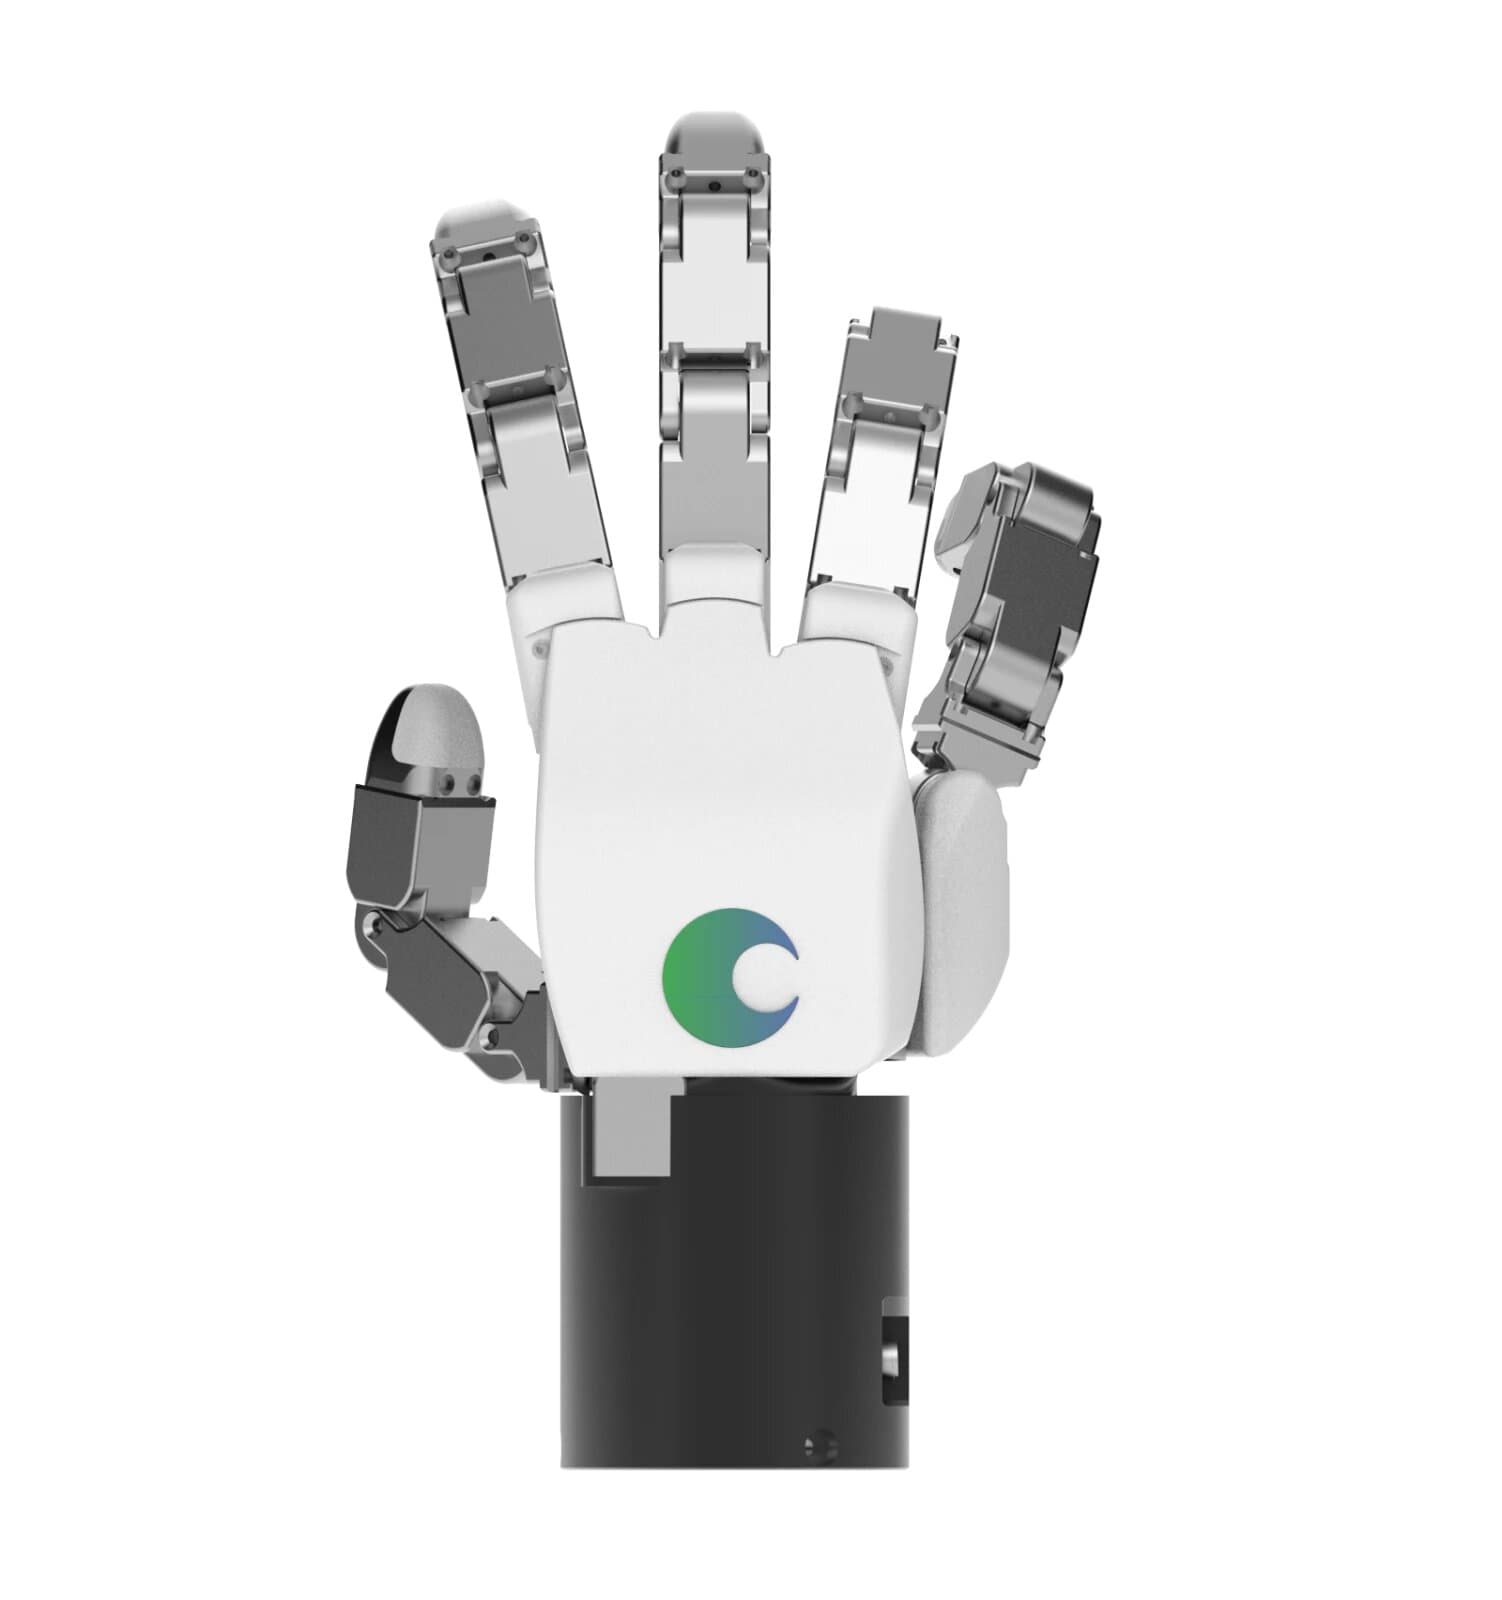
エンドエフェクタ
Tesollo
DG-5F-M
Five-finger anthropomorphic robotic hand
価格
価格はお問い合わせ
According to Tesollo, DG-5F-M is a fully actuated five-finger hand with 20 independently controlled joints, four per finger, for dexterous manipulation and robotics research. Fingertip force, torque and tactile sensors are optional. The maker publishes separate rated and maximum pinching and enveloping capacities, which depend on object friction; no single payload is asserted here. Contact the maker for pricing.
仕様
- 重量
- 1.763 kg
- 電圧
- 24 V
- 周波数
- 250 Hz
- プロトコル
- Modbus (RTU, TCP), Ethernet (TCP/IP)
対応ロボット
対応情報はまだ登録されていません
dexterous-handhumanoid
同じカテゴリの部品
関連部品
エンドエフェクタ
AI render
エンドエフェクタ
AI render
エンドエフェクタ
エンドエフェクタ