Reachy 2
More actions
Open-source humanoid for bimanual manipulation and embodied AI research
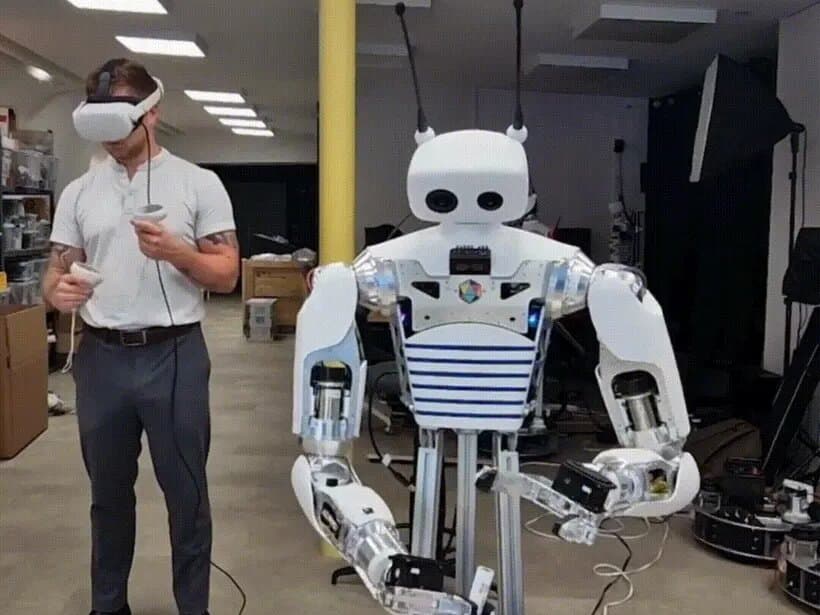
More from Pollen RoboticsAccording to Pollen Robotics, Reachy 2 is an open-source humanoid for embodied AI and object manipulation research. Its bio-inspired arms each have seven degrees of freedom and use Orbita 2D/3D parallel actuators. The specification summary reports approximately 3 kg payload per arm, adjustable height of 136–166 cm and full robot weight up to 50 kg. Stereo and RGB-D vision support perception, while ROS 2 Humble, a Python SDK and VR teleoperation support development and control. An omnidirectional mobile-base configuration uses three omniwheels, sensors and LiDAR.
Request a quote
Price
Quote-only — the maker does not publish a price. Request a quote for your configuration.
Request a quoteAlternatives
No comparable alternatives with enough catalog data.
Frequently asked questions
- How much does Pollen Robotics Reachy 2 cost?
- Quote-only — the maker does not publish a price. Request a quote for your configuration.
- What are the alternatives to Pollen Robotics Reachy 2?
- No comparable alternatives with enough catalog data.
- Is Pollen Robotics Reachy 2 still sold?
- Current availability is not verified. Confirm sales and stock with the maker.
Specifications
Use cases
- •Embodied AI research
- •Object manipulation
- •VR teleoperation
SDKs & programming
Source-reported details
These fields preserve wording reported by manufacturer or regulatory sources. They are not standardized comparison metrics; verify current details with the official source.
- actuators
- Orbita 2D/3D parallel actuators
- adjustableHeight
- 136–166 cm
- armDegreesOfFreedom
- 7 per arm
- fullRobotWeight
- Up to 50 kg
- mobileBase
- Omnidirectional mobile-base configuration with three omniwheels, sensors and LiDAR
- payloadPerArm
- Approximately 3 kg per arm
- software
- ROS 2 Humble + Python SDK
- vision
- Stereo + RGB-D
Build a DIY version
Turn this robot’s use cases into a small DIY prototype.