CocoaScout RTK: Autonomiczny łazik do analizy gleby
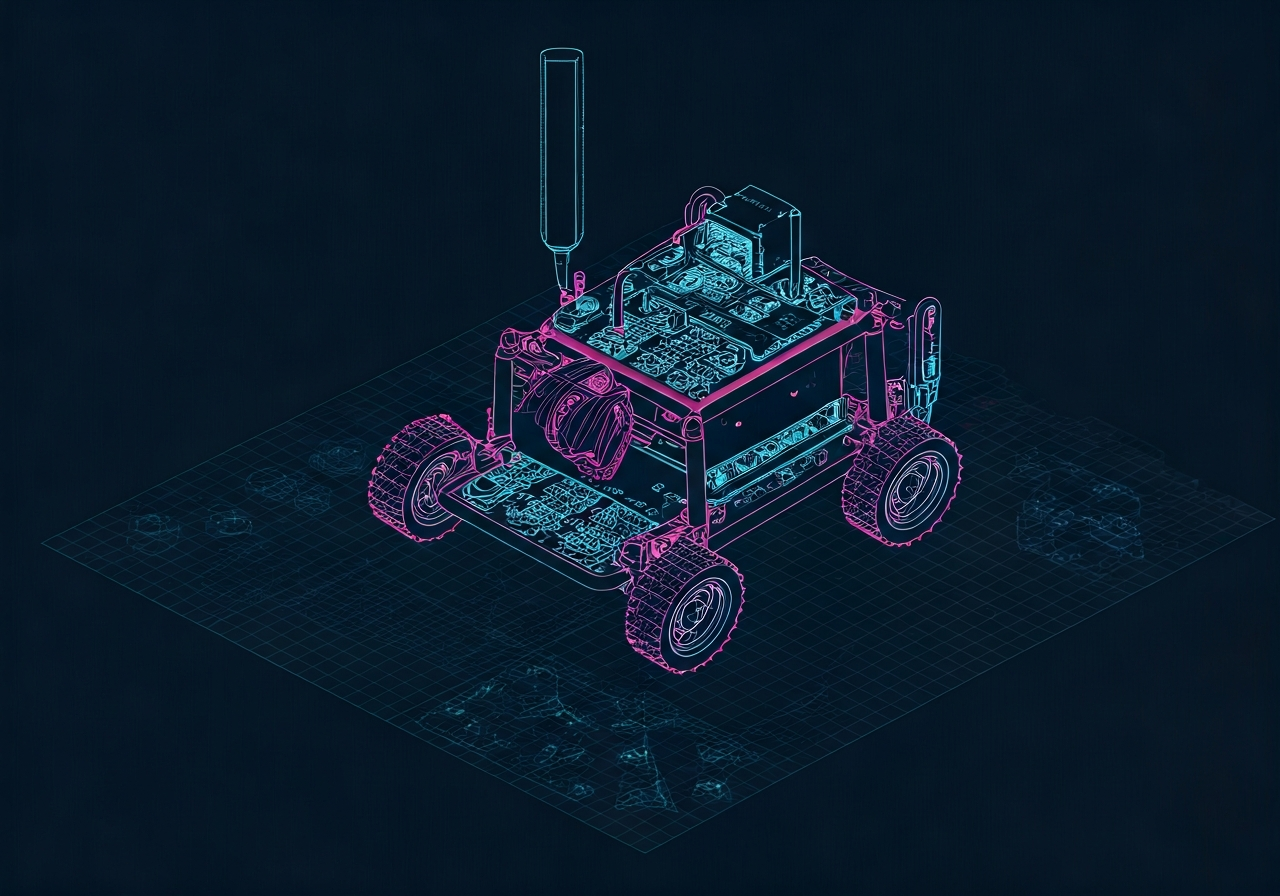
Wytrzymały, autonomiczny łazik 4WD zaprojektowany do poruszania się po gęstych plantacjach kakaowca, wykorzystujący RTK-GPS i LiDAR do precyzyjnego mapowania stanu gleby. Posiada zmotoryzowaną sondę automatyzującą pomiar NPK i wilgotności, synchronizując dane przez MQTT do zarządzania uprawą w czasie rzeczywistym.
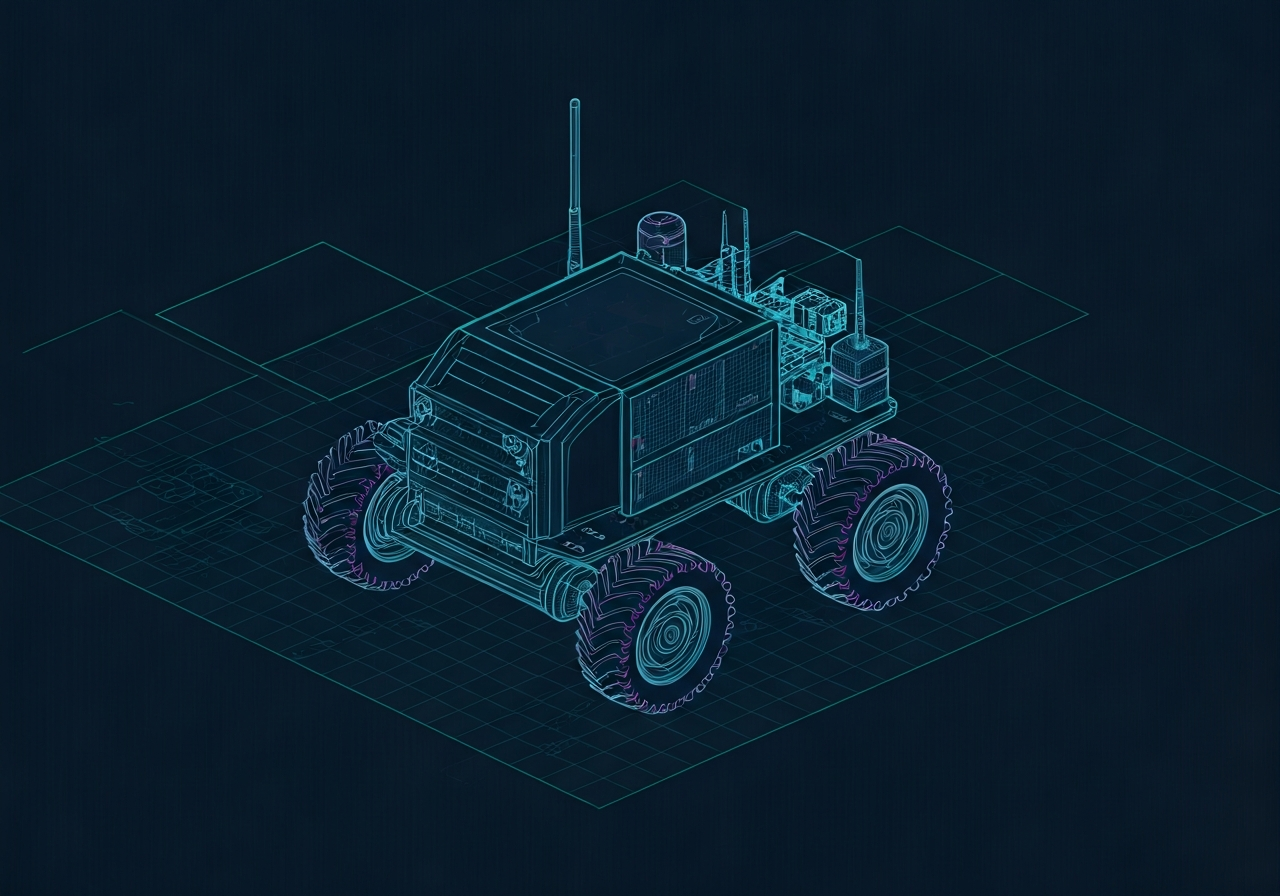
Original prompt (angielski)
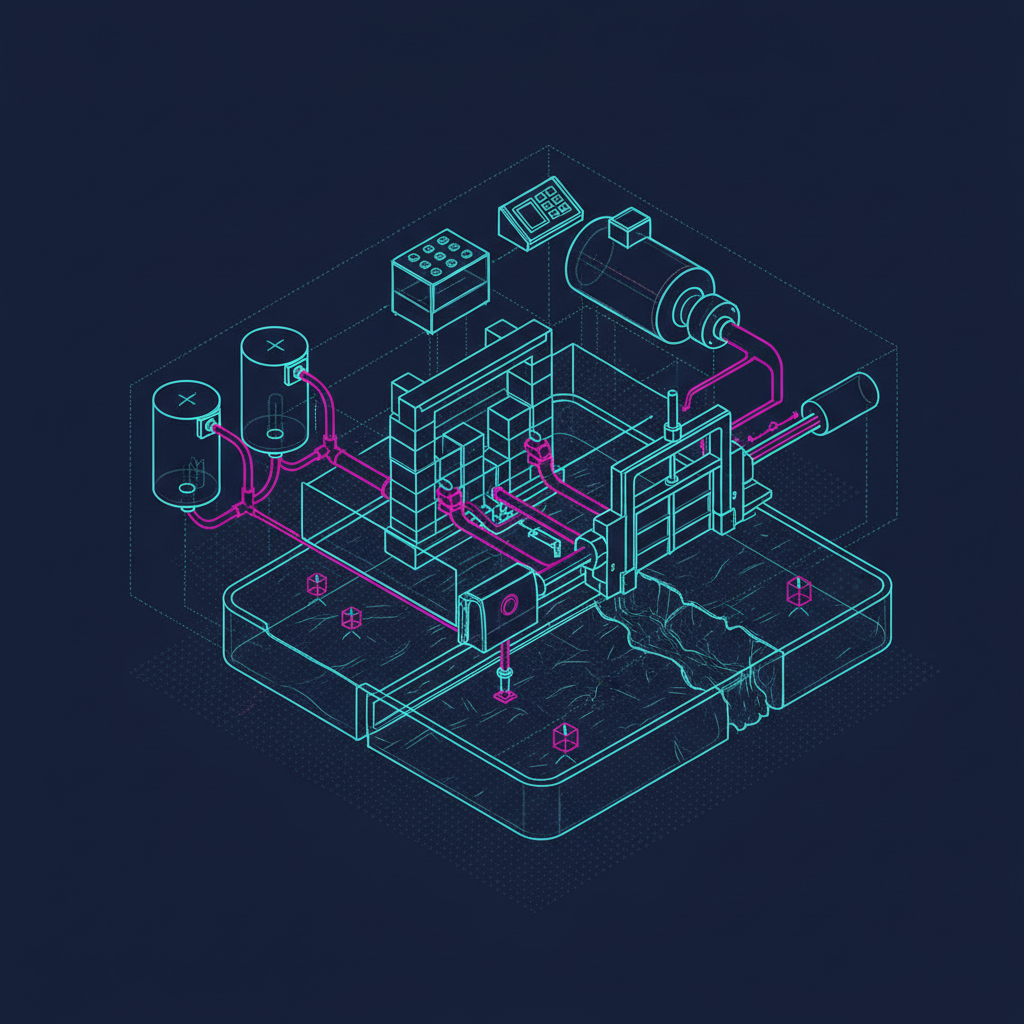
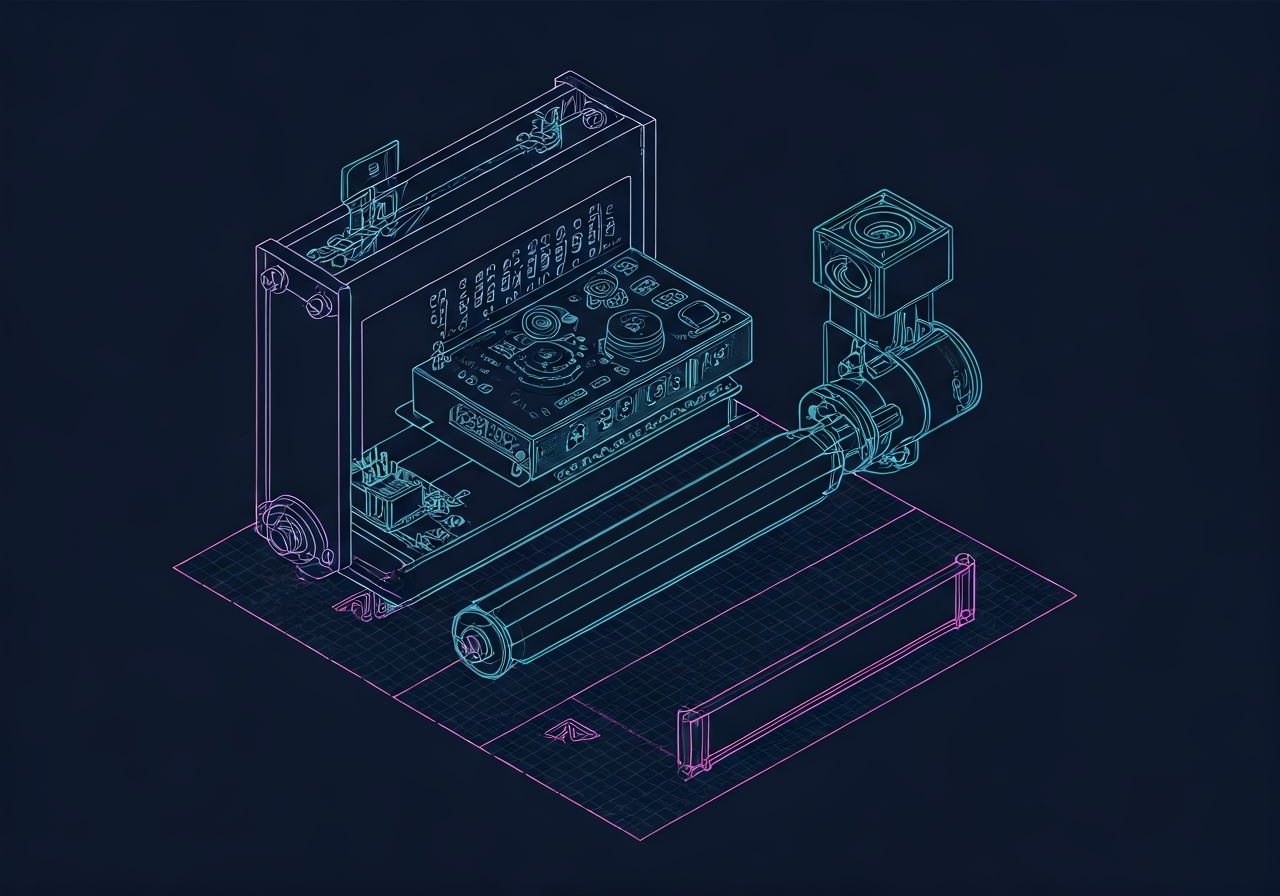
Design an autonomous cocoa farm monitoring robot using Jetson Nano 4GB. The robot navigates between RTK-GPS waypoints, avoids obstacles, and collects soil data at predefined locations. At each setpoint, a linear actuator lowers a soil probe into the ground to measure moisture, temperature, pH, EC, and NPK, then retracts it before continuing. Include a rugged chassis for muddy terrain, 4WD or tracked locomotion, LiDAR, camera, ROS integration, MQTT communication, power system, electronics architecture, BOM, and CAD-ready mechanical concepts.
Like this idea? Build it.
Open the Builder pre-filled with this concept. Get a real BOM, render, schematic and firmware in 30 seconds.